

Explore Opportunities in This AI+X Domain
Indicate your interest to receive relevant AI+X pathway updates and future opportunities in this field.
PBL
Tesla Optimus Project
Humanoid Robotics and Embodied AI
Work through the core challenges of humanoid robotics — motion and balance, perception, manipulation, and autonomous behavior — by programming a simulated Unitree G1 humanoid in Python and MuJoCo, testing behaviors, observing failures, and improving performance.

Project
Tesla Optimus Project
Location
Online
Duration
8 Weeks
Upcoming Sessions
Jan. 04 - Mar. 05, 2027
Outcomes
Turn camera pixels into robot decisions and reactions
Apply inverse kinematics to reach and grasp objects
Plan arm trajectories that respect workspace limits
Build autonomous robot behaviors with state machines
Combine sensing and motion in perception-action loops
You Will Get
Industry Guidance
Work directly with our project leads—experts and top researchers—who bring their real-world insights and expertise straight to your learning experience.

Research Experience
Collaborate with teammates and the project lead in a multi-week project to pursue novel questions in your research field.

Peer Networks
Engage with our PBL participants from all over the world. Collaborate with new peers and learn about their own research endeavours.

A Strong Portfolio
Put your best foot forward in the PBL with a standout project and receive a PBL Evaluation Report that can be used as a recommendation letter for employers and grad schools.
Expert Guidance
Get personalized feedback to grow your research and innovation skills.

Deliverables
Real projects, lasting connections, and new opportunities beyond your program.
Project Deliverables
The final presentation of your 8 weeks could be a poster, written report, or a slide deck, all of which can be expanded on.
Research Extension
Utilize up to 5 additional meeting times with the project lead after the project’s conclusion to build your work out for publication or conference presentation.
Industry Network
Meet peers in your projects and participate in a global talent community both online and in-person.
Industry Application
Tesla is developing Optimus, a general-purpose humanoid robot meant to take on repetitive and physically demanding work, starting with tasks inside Tesla's own factories. Optimus has to solve the same problems this PBL covers: keeping balance while walking, seeing and locating objects, reaching for and handling items, and stringing actions together into tasks it completes on its own. Students will gain hands-on experience with the core technical problems behind a humanoid like Optimus.
Popular Industry Positions
Robotics Controls Engineer
Design control systems that keep legged and humanoid robots stable while they move.
Robot Perception Engineer
Build vision systems that let robots locate, track, and respond to objects around them.
Embodied AI / Robot Learning Engineer
Develop decision-making and behavior systems that let robots complete tasks autonomously.
Tracks
Track 1
Controlling Balance and Motion in a Humanoid Robot
Program a simulated humanoid to perform coordinated movements while maintaining balance and stability.
Program standing, squatting, waving, and walking motions for a simulated Unitree G1 in MuJoCo
Coordinate hip, knee, ankle, waist, and arm joints in Python
Tune movement speed, joint angles, gait parameters, and stabilization settings
Measure stability and body tilt, and identify the conditions that cause falls
Design a new movement or improve an existing one while limiting instability
Track 2
Perceiving and Reacting Through a Robot's Camera
Build a perception system that lets a simulated humanoid find targets from its own camera view and turn to react to them.
Work with a simulated camera mounted on the humanoid in MuJoCo
Test how distance, position, height, and viewing angle affect what the robot can see
Detect targets from camera pixels with color or object detection in OpenCV
Program the robot to search for a target outside its field of view and orient toward it
Compare decisions made from camera images with decisions made from perfect simulator data
Track 3
Reaching, Grasping, and Moving Objects with Robot Arms
Program a simulated humanoid arm to reach, grasp, and move objects, and measure why some grasping strategies fail.
Control the shoulder, elbow, and wrist joints of the Unitree G1 arm in MuJoCo
Apply inverse kinematics to place the hand at a target position
Plan trajectories within workspace limits while avoiding collisions
Progress from touching and pushing objects to moving them from one point to another
Measure accuracy and efficiency across object positions and grasping strategies
Track 4
Building Autonomous Multi-Step Behaviors for a Humanoid
Build a behavior system that lets a simulated humanoid detect an object, decide what to do, and complete a multi-step task on its own.
Combine perception, decision-making, and motion in a perception-action loop
Design multi-step behaviors with state machines and simple AI decision rules
Sequence detecting, orienting, reaching, and acting into one autonomous task
Test behaviors in changing simulated environments with sensors and cameras
Measure task success and identify where the behavior breaks down
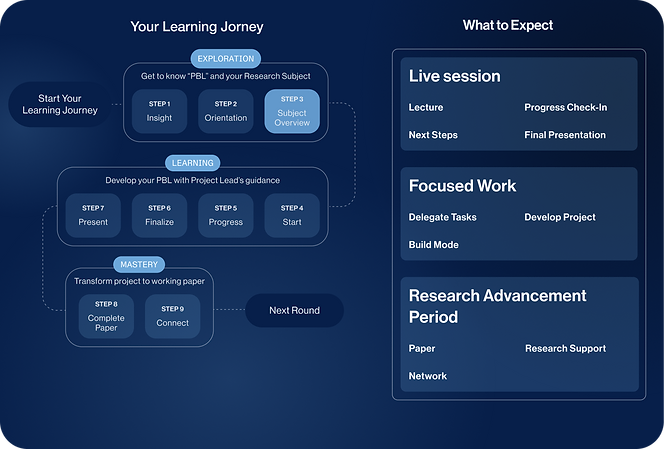
PBL Journey
Online PBL Projects meet once a week for 8 weeks, and follow the research project format. Participants will meet the project lead, learn the conventions of the field and familiarize themselves with the tracks, then spend the middle portion of their time collaborating to develop their research.
At the end, participants will present their final project and receive feedback, with the opportunity to extend their timeline and develop the project in greater depth.
Project Team
Our Academic Team plays a vital role in your PBL journey at Blended Learning. We are dedicated to enhancing your learning experience and ensuring your academic success. Our team consists of three distinct roles, each with a specific focus to support your Research Guidance, Project Progress, and Personal Growth.

Project Lead
Providing Industry and Research Guidance
CalTech Robotics Researcher and Engineer in Humanoid Robotics and Autonomous Systems
He specializes in autonomous systems, computer vision, humanoid robotics, and advanced robotic platforms. He previously worked on robotics research at MIT, including the Roboat autonomous robotic boat project, and before that developed industrial exoskeleton and in-pipe robotic systems in Europe. He later joined UBTECH Robotics, contributing to next-generation robotic technologies. He holds a Ph.D. in Electrical Engineering from TU Wien and received the 2014 OVE Prize for his work on robotic inspection and repair of freshwater pipelines.

Academic Advisor
Tracking Your Project Development
The Academic Advisor is dedicated to your project completion success. They manage the progress of your PBL, guiding team formation, facilitating group discussions, and resolving conflicts. Additionally, the Academic Advisor ensures team member contributions are on track and provides logistical support, including attendance tracking, hosting recitation sessions, managing research support requests, and conducting student evaluations at the end of the PBL.
From Our Students
"After a night spent debugging, I suddenly discovered the program running perfectly. In that triumphant moment, you realize your true capability and success. The exhaustion fades, replaced by the thrill of knowing your skills and persistence led to this achievement, reaffirming your potential."

Nicole Y.
National University of Singapore
B.S. Economics
FAQs
What is the learning format of a PBL?
All PBLs are offered in an 8-week online format that begins with an orientation followed by subject setup overview of the different tracks. The majority of the session time is dedicated to project development, with a final presentation at the culmination of the 8 weeks. Many PBLs are also offered bi-annually in an on-campus format that consists of daily in-person meetings.
How long does each PBL cohort last?
One round of the Online PBL cohort lasts 8 weeks, preceded bys a pre-PBL orientation week. Each On-Campus PBL usually has 8 in person meetings, with intensive classroom education and collaboration. This means the biggest difference between online and on-campus PBLs is time participants have in between meetings.
How can I be more academically prepared before the PBL starts?
Review the Blended Learning Insights sent by the Academic Advisor and familiarize yourself with the project topic and pre-learning materials. Ensure you have all necessary softwares and other resources needed for the PBL.
For each PBL cohort, will I work in teams? Are PBL team members self-selected or assigned?
Yes, you will work in teams for each round of the PBL Cohort. Each team has 3 to 6 participants, organized by the Academic Team. The Academic Advisor will organize groupings based on students' backgrounds, preferred track, and skills.
Can I work with the Project Lead on my project after the PBL ends?
Yes, with your AI + X Research Plan, you may request up to five PBL Research Extension meetings, where you work with the project lead to develop your project into a working manuscript. To schedule a PBL Research Extension meeting, talk to your Academic Advisor at the conclusion of your PBL.
What do I receive at the end of the PBL?
At the conclusion of the PBL cohort, you can request a PBL Evaluation Report which summarizes the PBL content, the hours you spent, the track you chose, and includes a recommendation letter from the Project Lead (for eligible participants who completed the project successfully).
Is attendance mandatory for PBL Live Sessions and Recitation Sessions?
Yes, attendance is mandatory for both PBL Live Sessions and Recitation Sessions. Participants with three or more unexcused absences forfeit their eligibility for a PBL Evaluation Report.
Do I need to have my camera on during online PBL Live Sessions?
Yes, you must have your camera on during online PBL Live Sessions. Participants with cameras off will be marked as absent. This is meant to encourage active engagement and participation in meetings.
Explore PBLs

Tesla Optimus Project
Humanoid Robotics and Embodied AI
Work through the core challenges of humanoid robotics — motion and balance, perception, manipulation, and autonomous behavior — by programming a simulated Unitree G1 humanoid in Python and MuJoCo, testing behaviors, observing failures, and improving performance.


